First, let me thank everyone for a very successful Steam Next Fest. Your support really means a lot. As we are nearing the Early Access release of JOY OF PROGRAMMING (the exact Date in Q1 2024 will be revealed soon), it's time to shorten the wait and show off another programmable device! Today we'll look at a programmable robot arm with inverse kinematics.
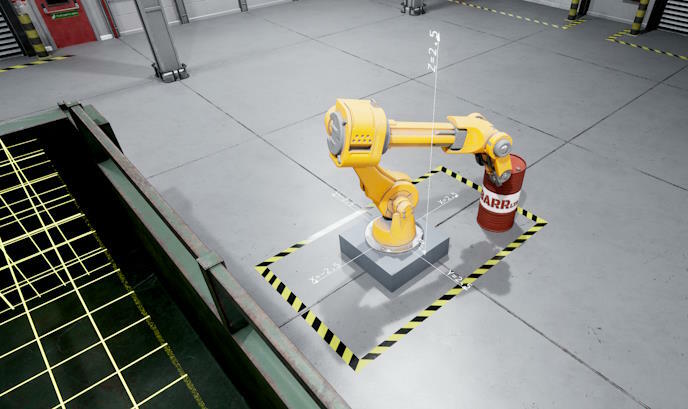
With the integrated IK system, you do not have to apply torque control to the individual motors of the arm, but rather can use a local coordinate system to directly set the desired position of the arm's grabber. Then you can pick-up most items, move the arm somewhere else and finally drop the item you are a carrying off again.
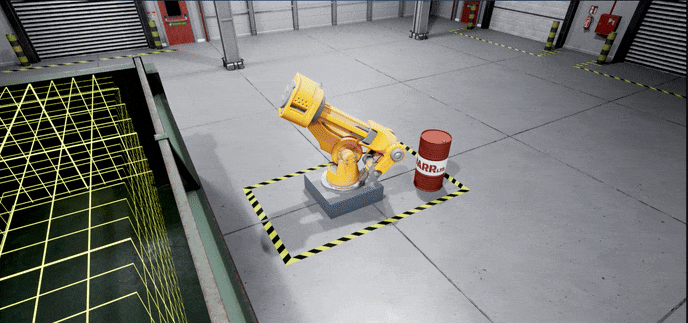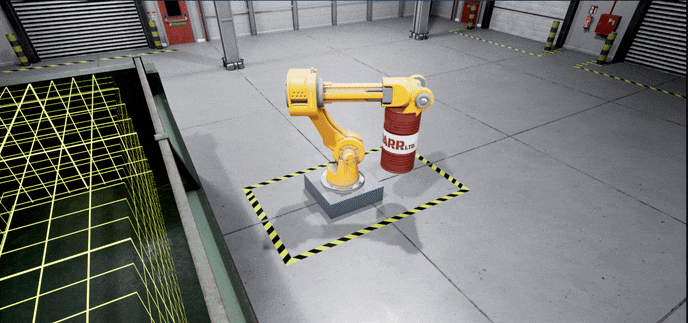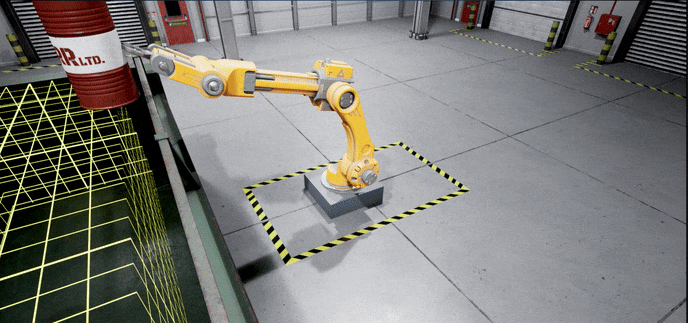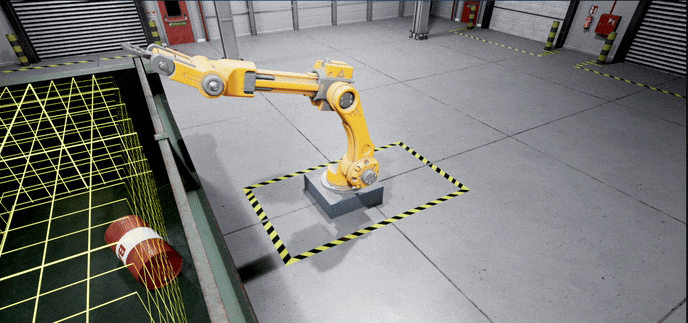
(Yeah, we don't talk about the clipping)
Using the robot arm is similar to using any other object in JOY OF PROGRAMMING:
arm = RobotArm.find("arm1")
#set position in local XYZ (forwards, right, up)
arm.set_grabber_location([1,0,1])
sleep(3) # wait to arrive
arm.pickup() # grab item
#change position
arm.set_grabber_location([-1,0.5,1.5])
sleep(3) # wait to arrive
arm.release() #drop off item
Happy Coding!